About Me
Wei Xiao 肖巍
- Reinforcement Learning
- Embodied Intelligence
Hi! I'm a PhD student at Fudan University and Shanghai Innovation Institute, advised by Li Zhang. I also work with Yao (Mark) Mu at ScaleLab@SJTU.
I've had the chance to work on reinforcement learning and embodied intelligence at Shanghai AI Lab, XPENG Robotics, and MiLab@Westlake. I earned my B.Eng. in Automation at Xiamen University, where I was advised by Qifeng Zhou.
I want to build end-to-end, general-purpose robotic systems that can eventually surpass human capabilities. I'm especially excited about robots learning beyond what we can demonstrate. I believe reinforcement learning and scalable learning approaches, such as world models and unsupervised/self-supervised learning, are key to getting there with less reliance on teleoperation data.
Feel free to drop me an email if you're interested in my research, have a collaboration in mind, or just want to chat!
xiaowei2002103@foxmail.com
News
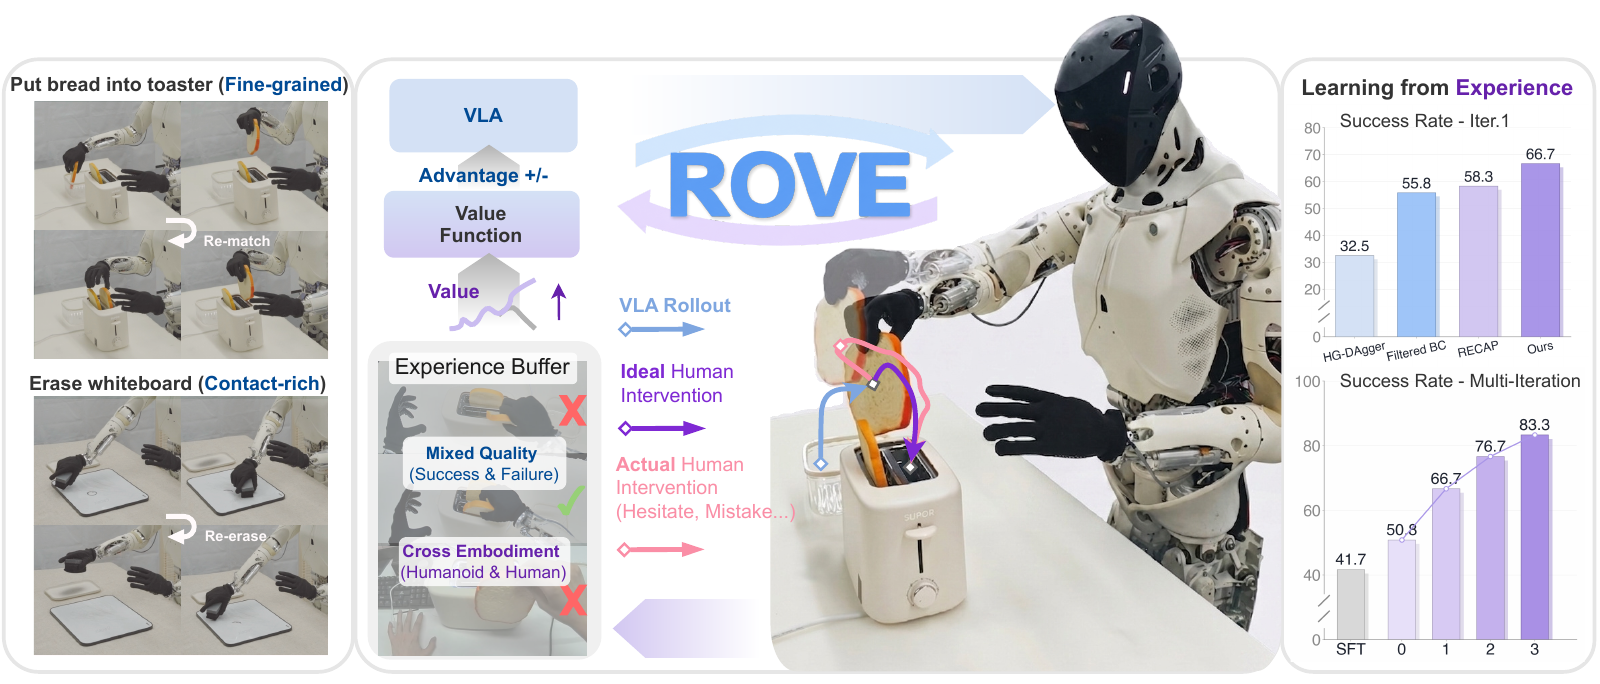
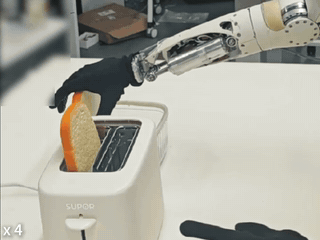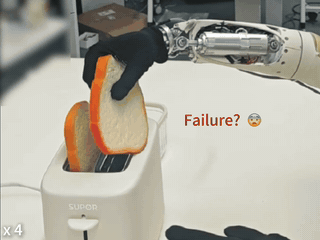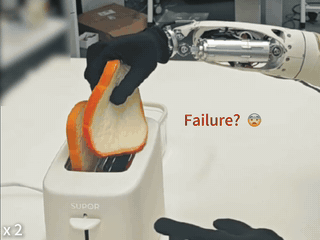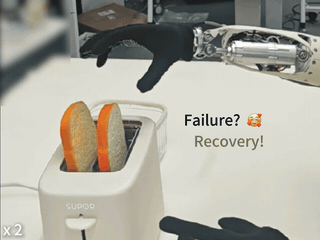
- Our work ROVE is available on arXiv.
- LIT is accepted by CASE 2026!
- KORR and TrajBooster are accepted by ICRA 2026, congrats to Jeffrey and Jiacheng!
- A summary of VLA+RL — Awesome-VLA-RL — is available on GitHub.
- Our works PORL and LIT are available on arXiv.
- Homepage has been set up.
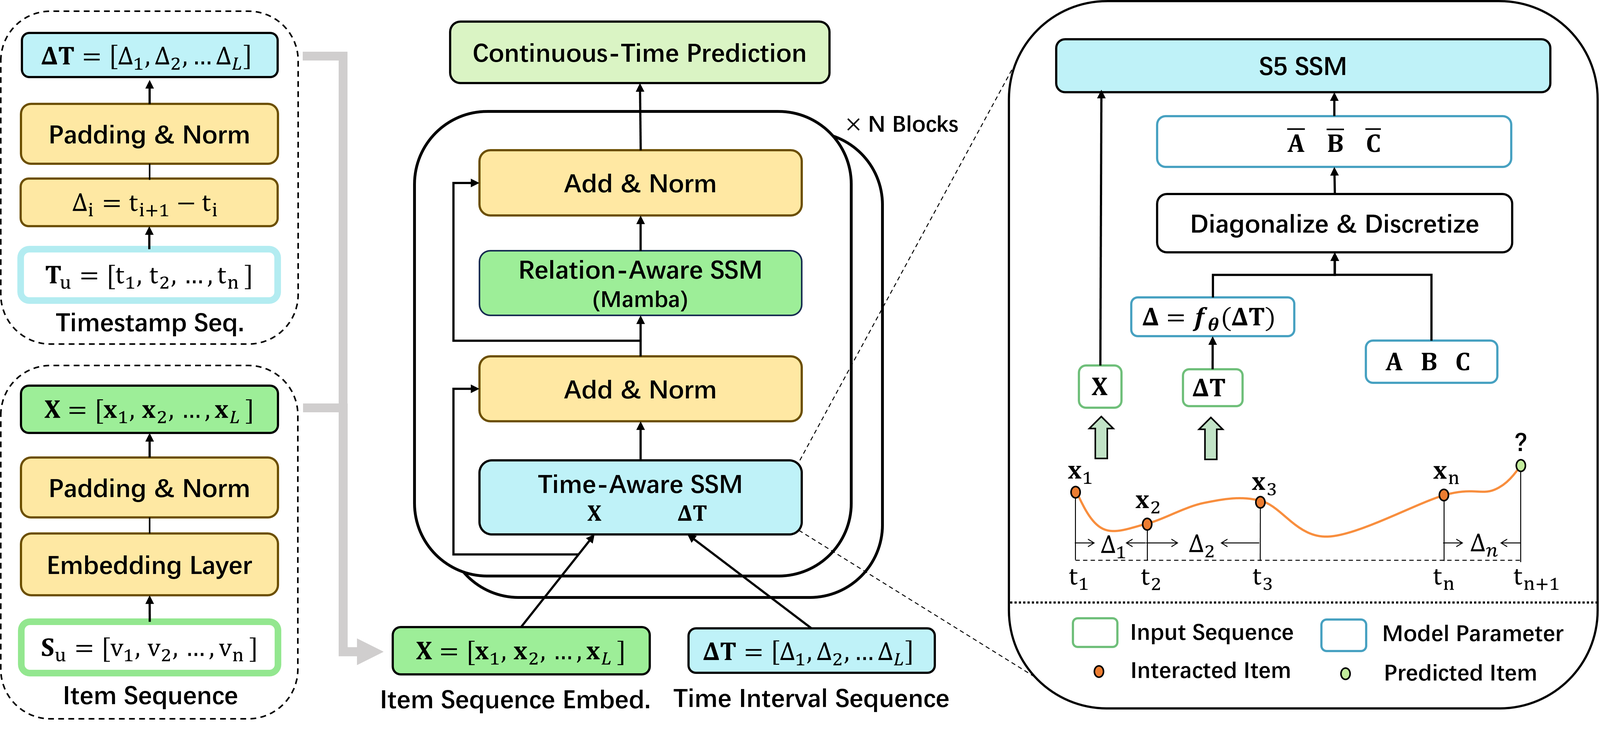
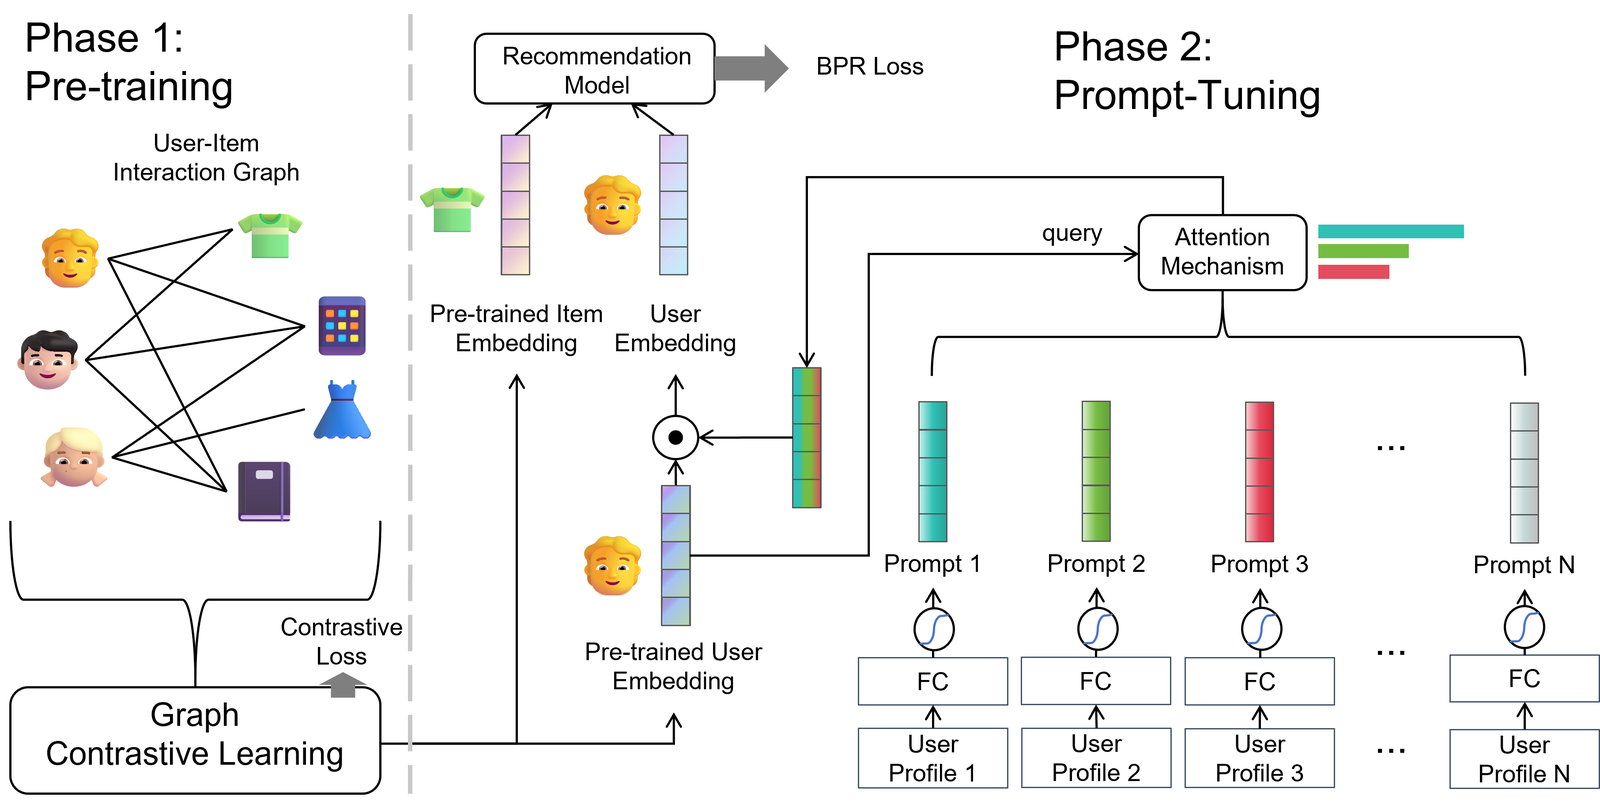
- Our paper PT4Rec is accepted by ACML 2024 and Machine Learning Journal.
Publications
Embodied AI & RL
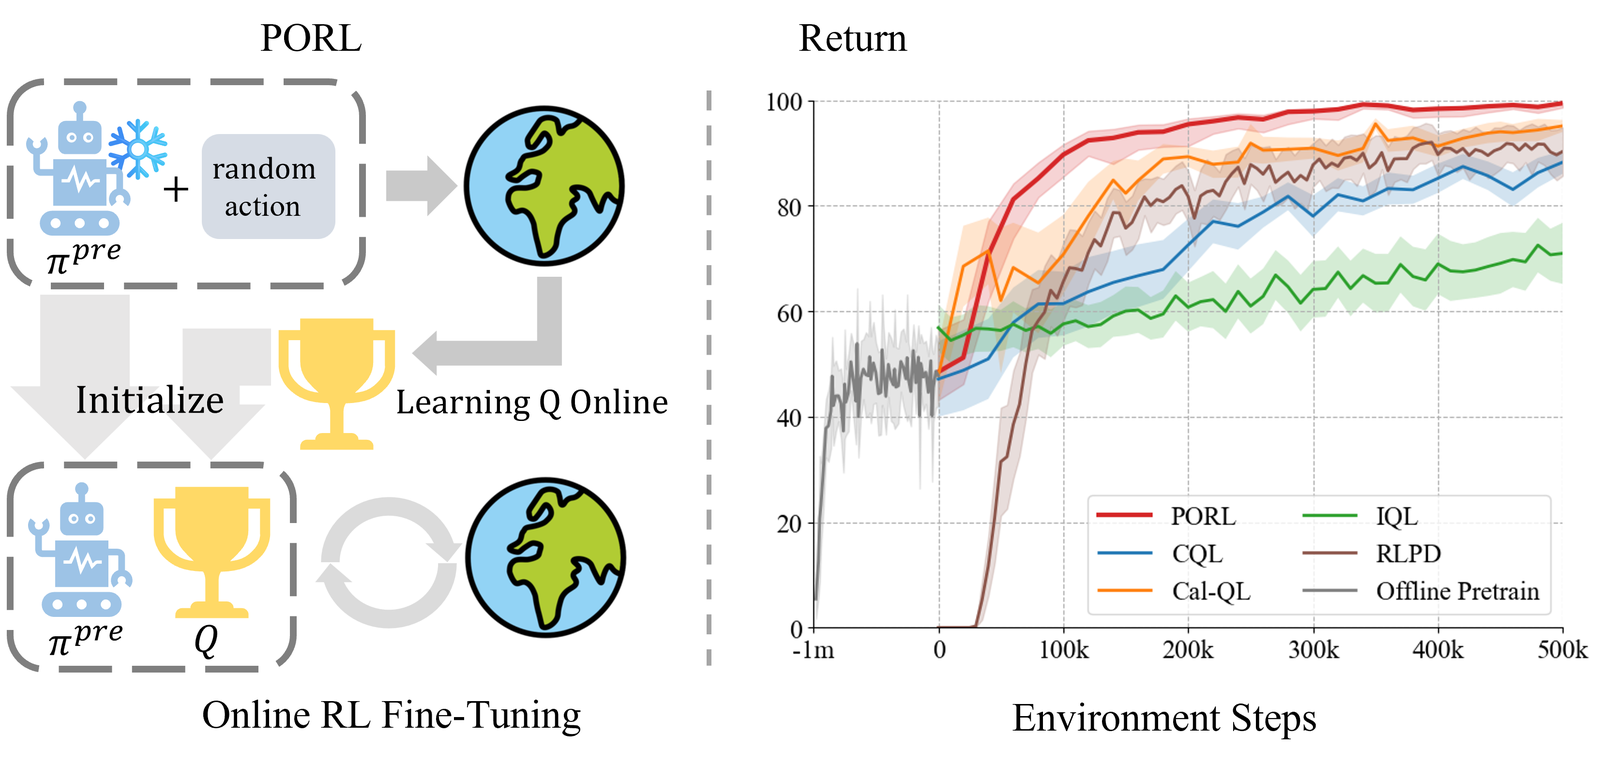

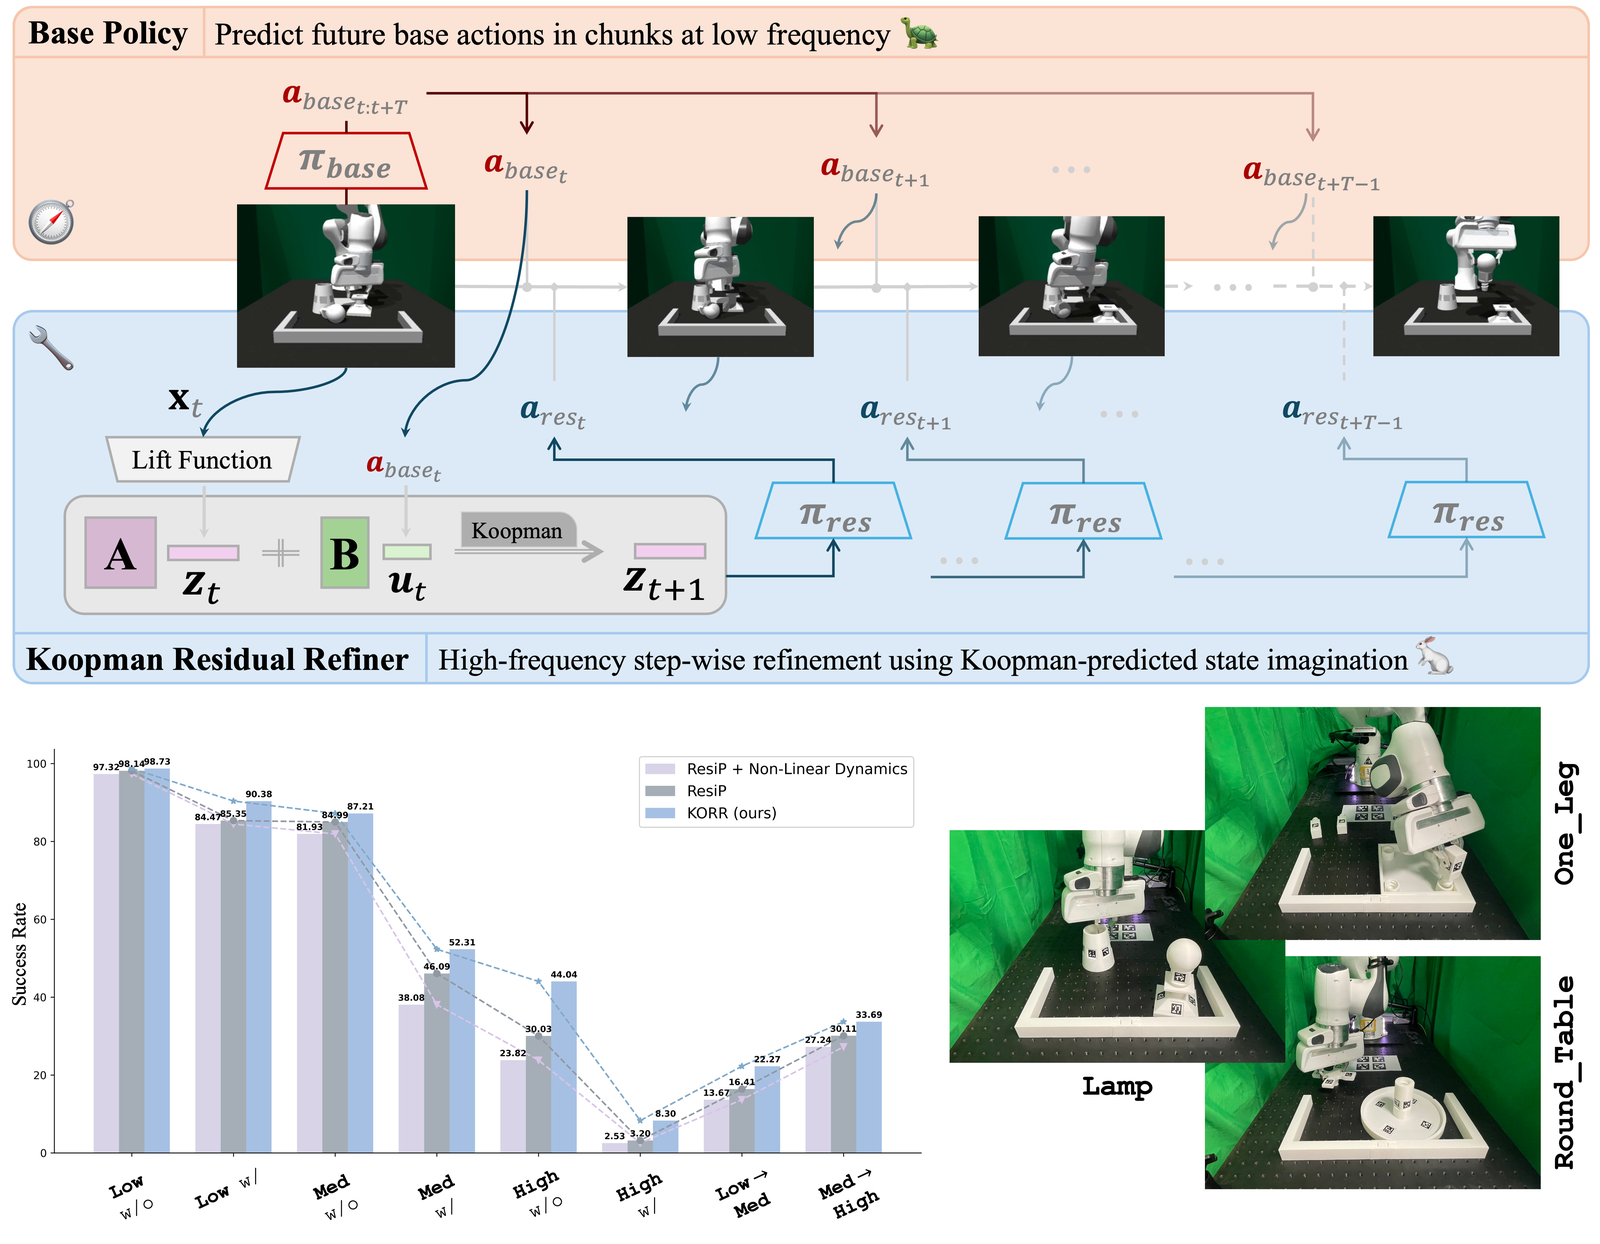
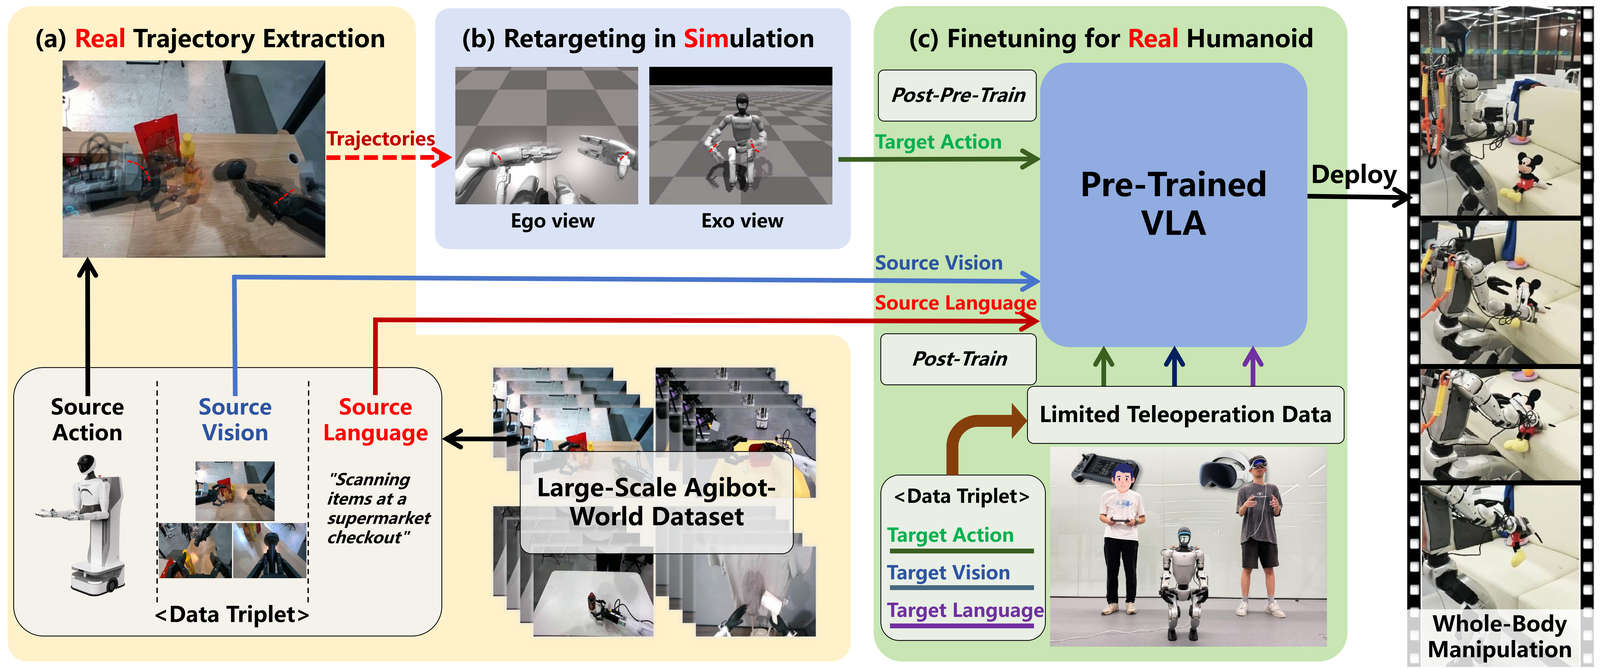
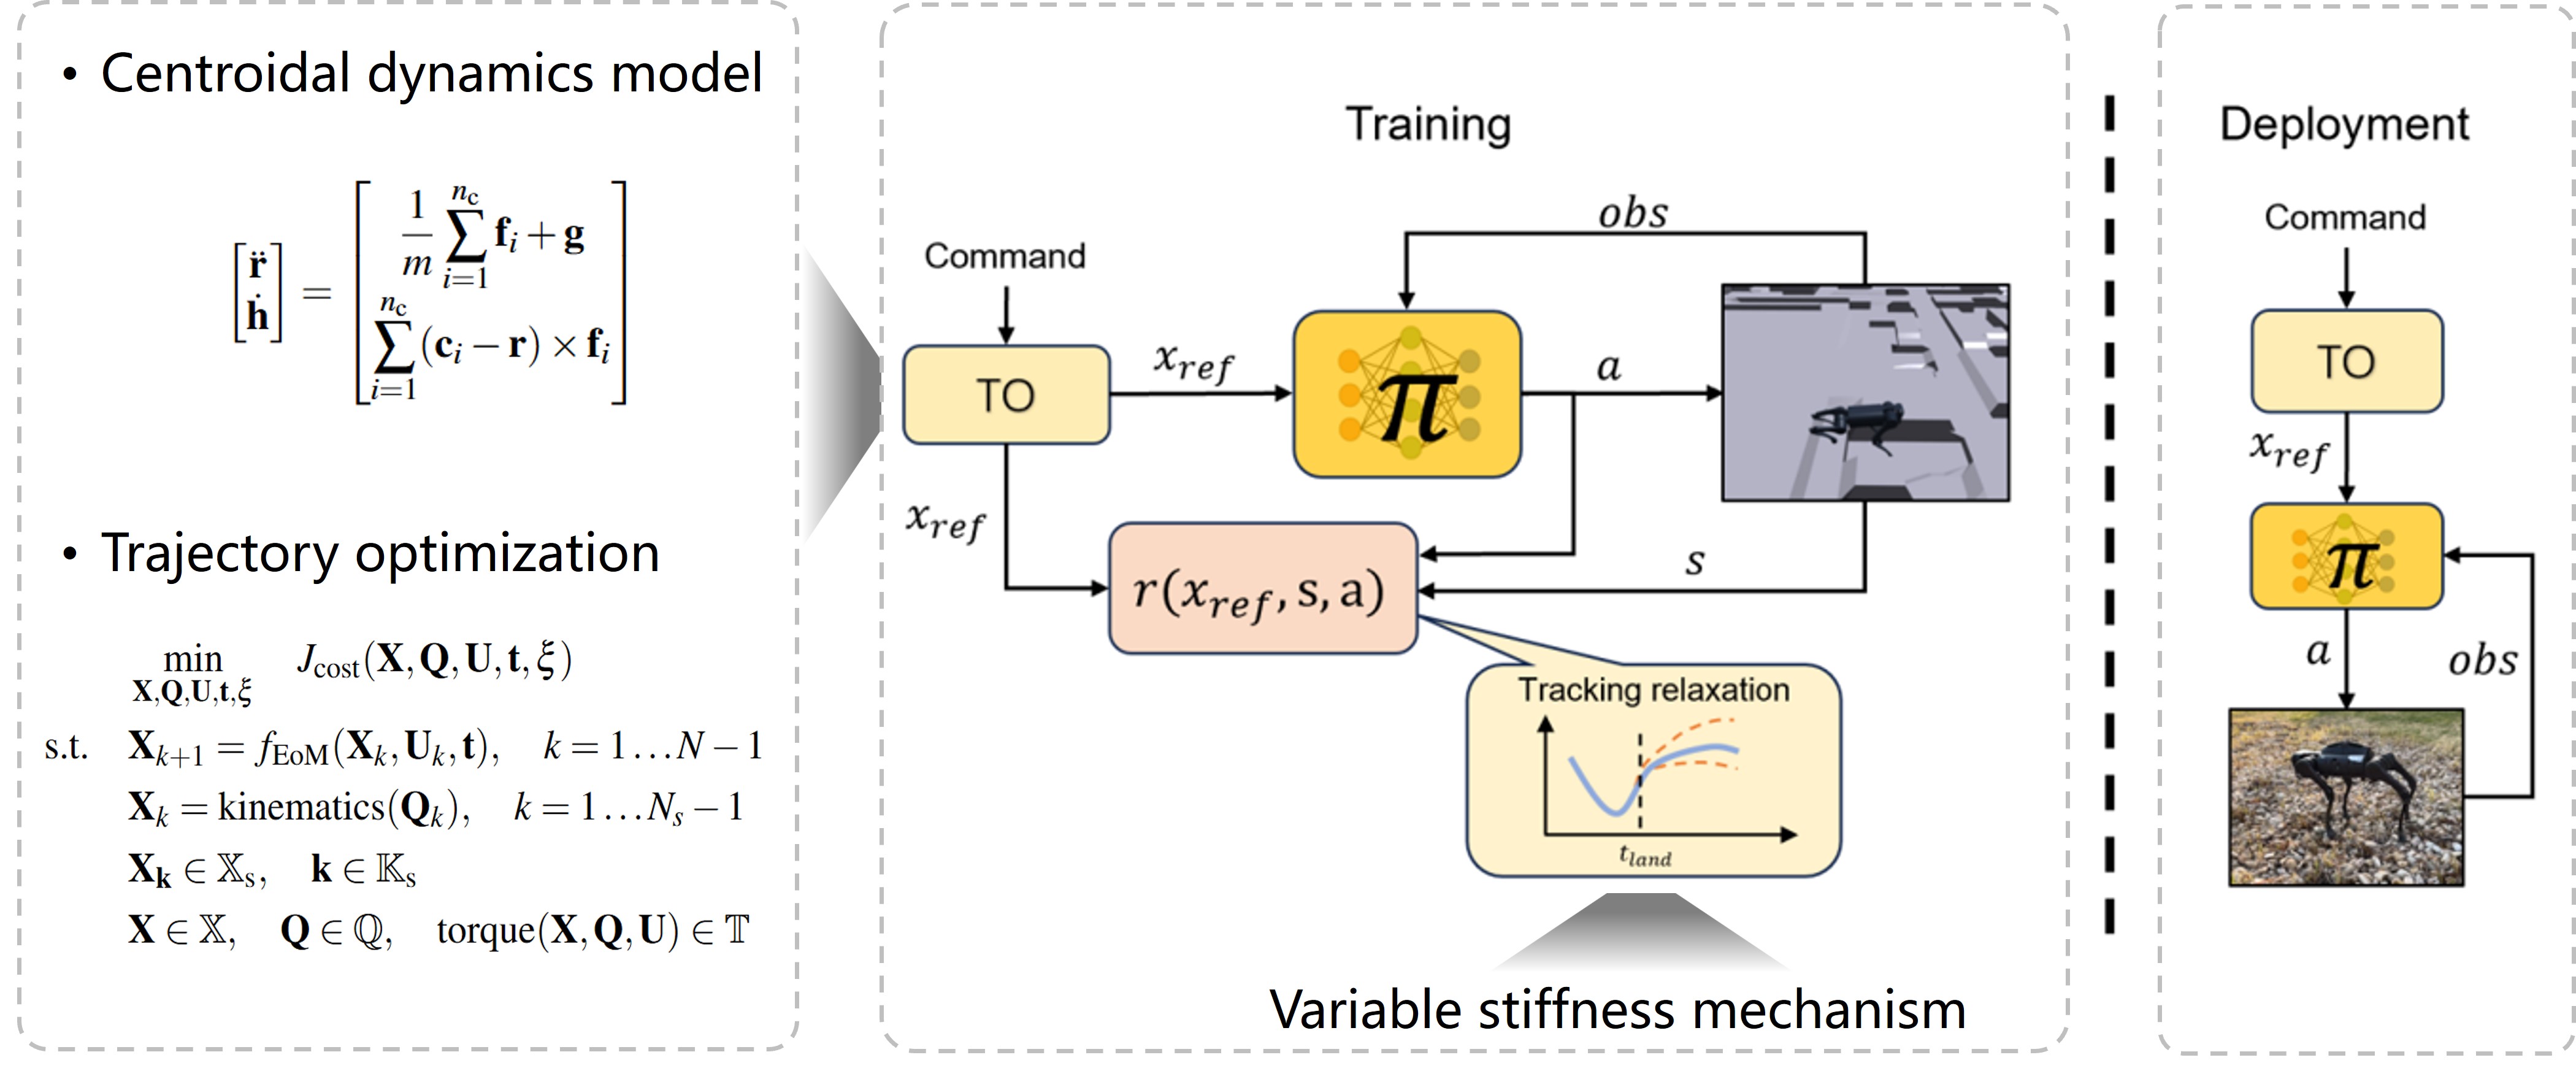
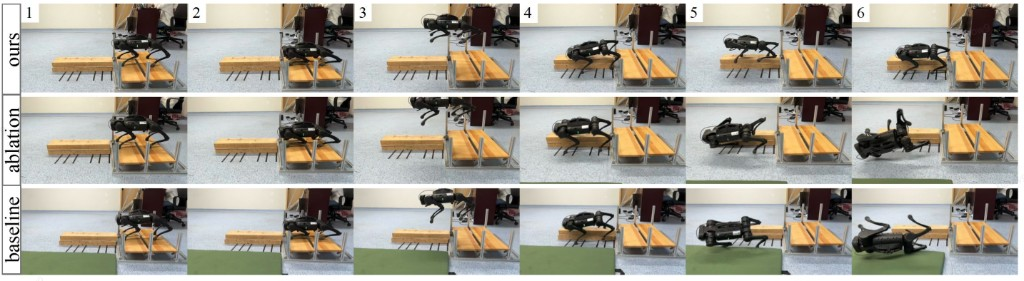
Integrating Trajectory Optimization and Reinforcement Learning for Quadrupedal Jumping with Terrain-Adaptive Landing
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025 (Oral)
Recommender Systems (Undergraduate Research)
Honors and Awards
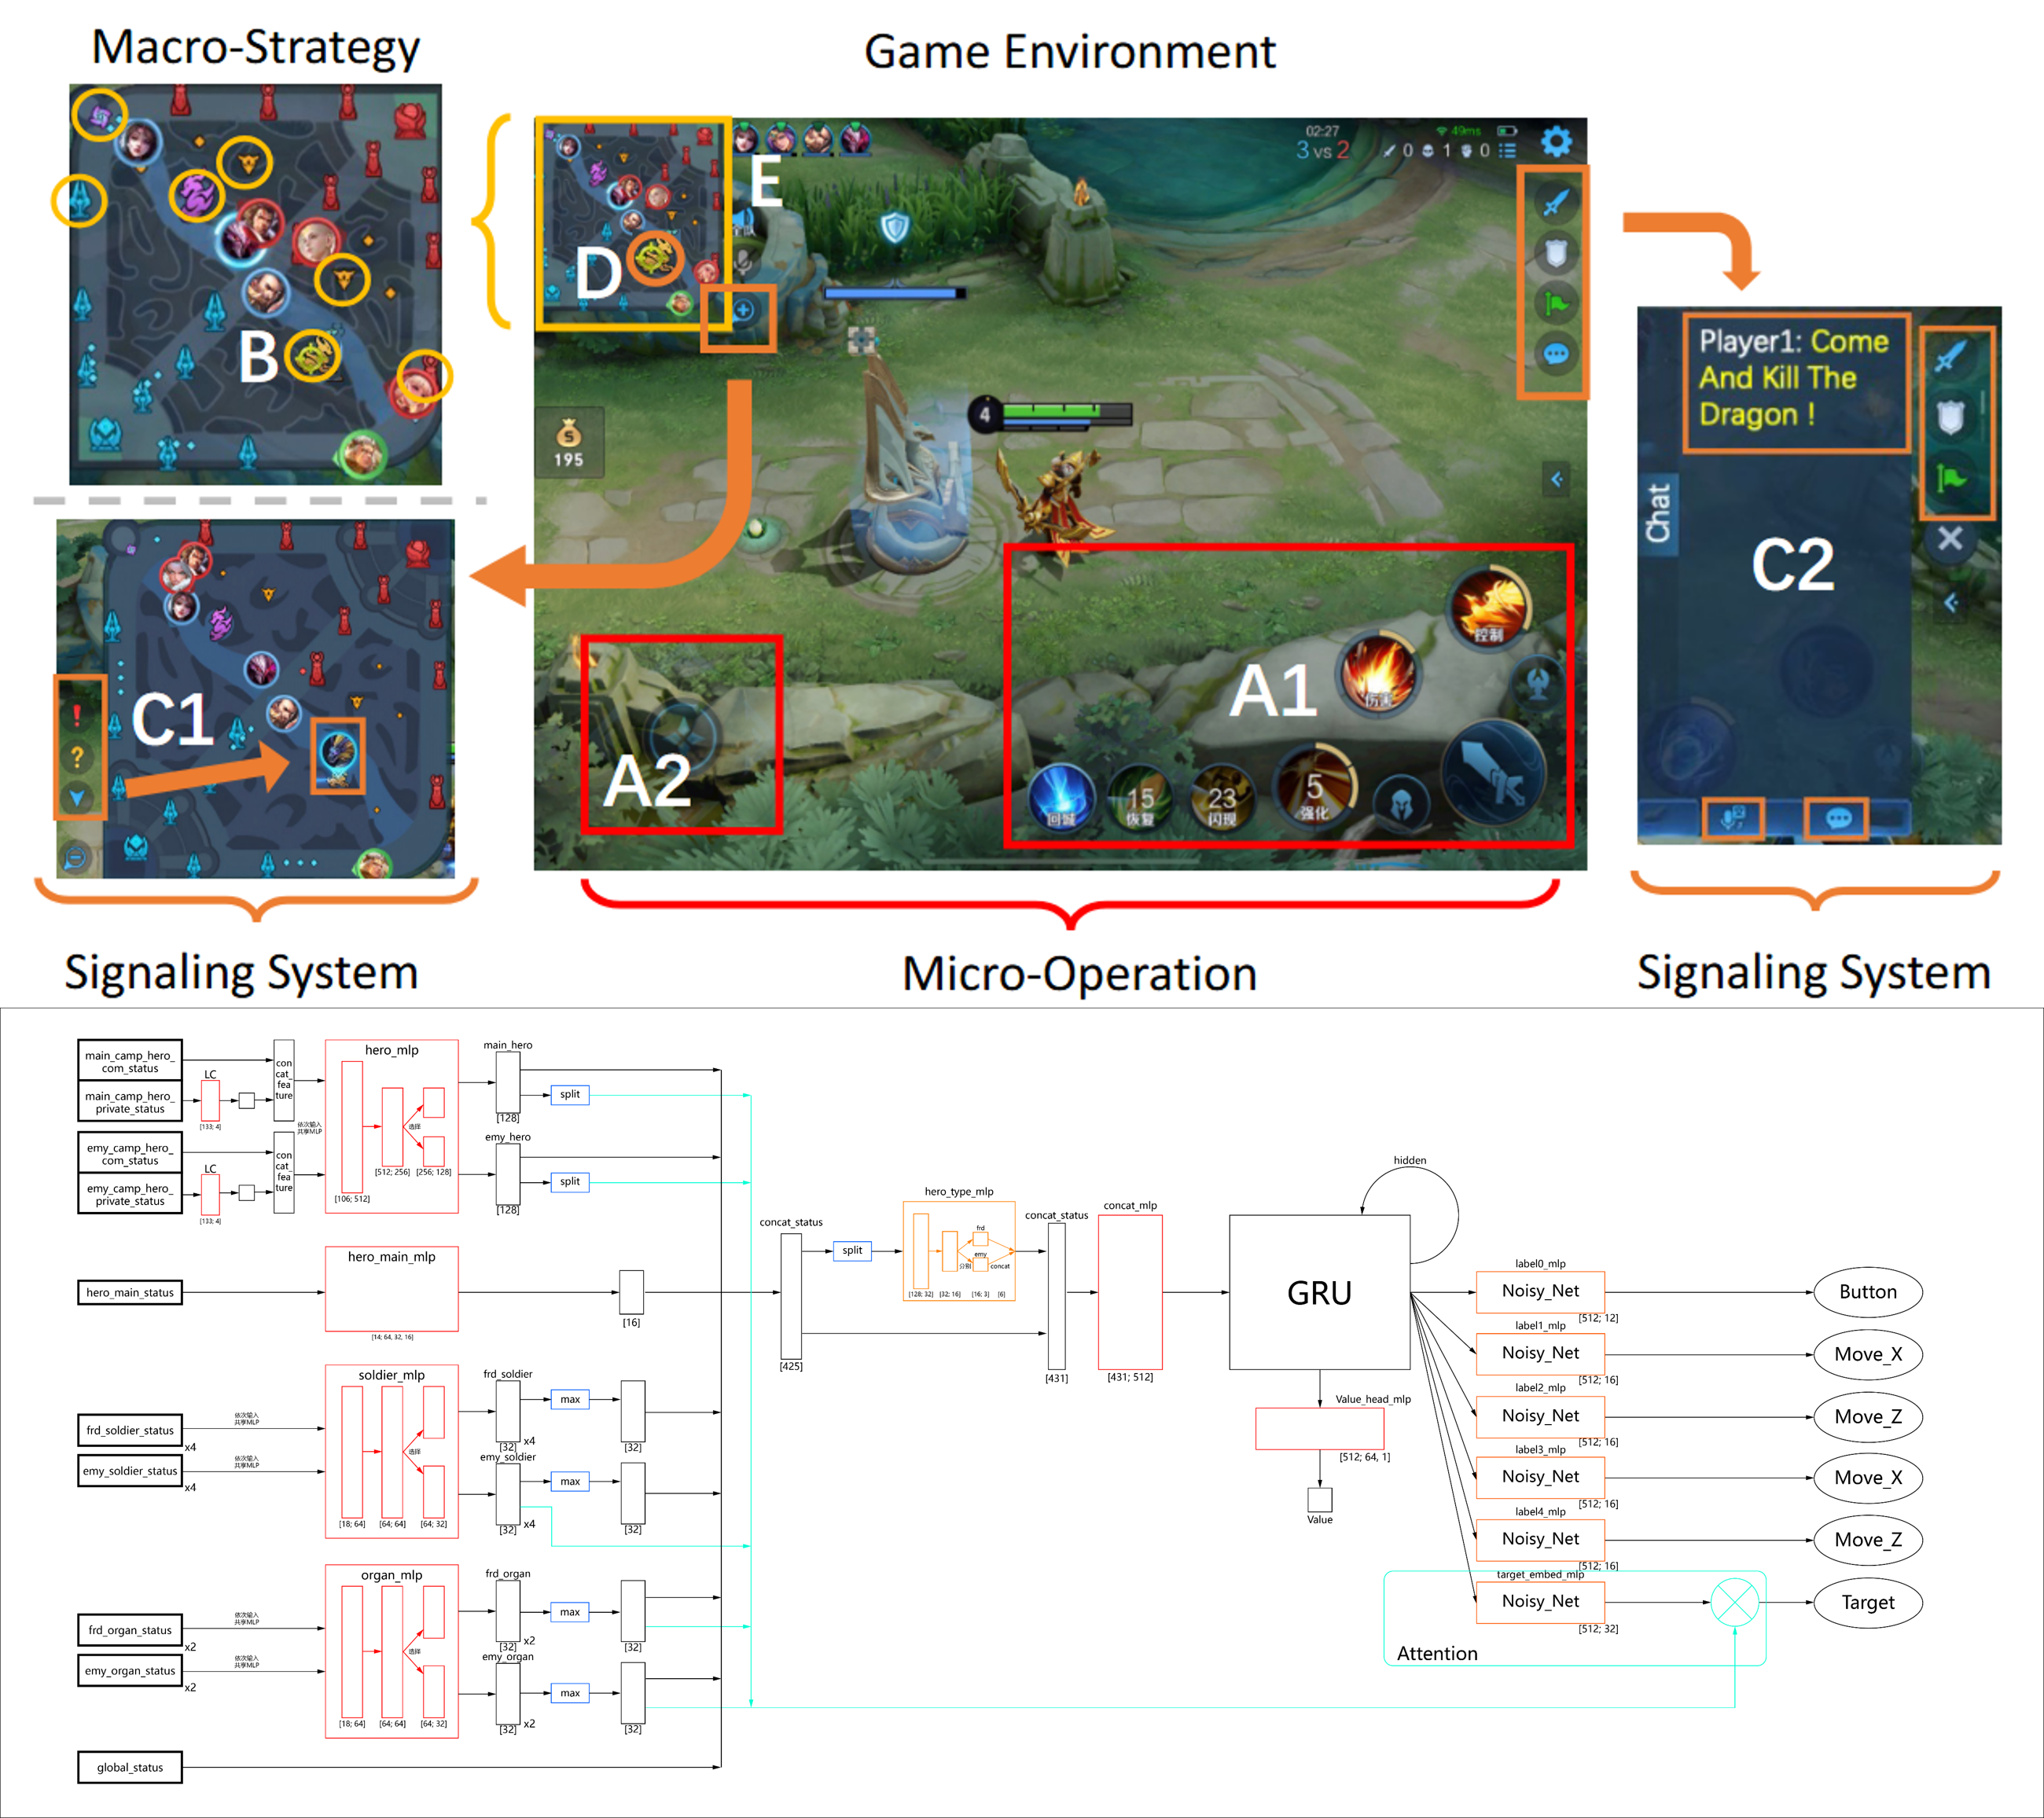
Tencent Kaiwu Reinforcement Learning Competition
Fourth Place (with Bonus ¥20,000) — 2023.12

Academic Service
- Conference Reviewer: IEEE International Conference on Robotics and Automation (ICRA), Conference on Robot Learning (CoRL), AAAI Conference on Artificial Intelligence (AAAI).
